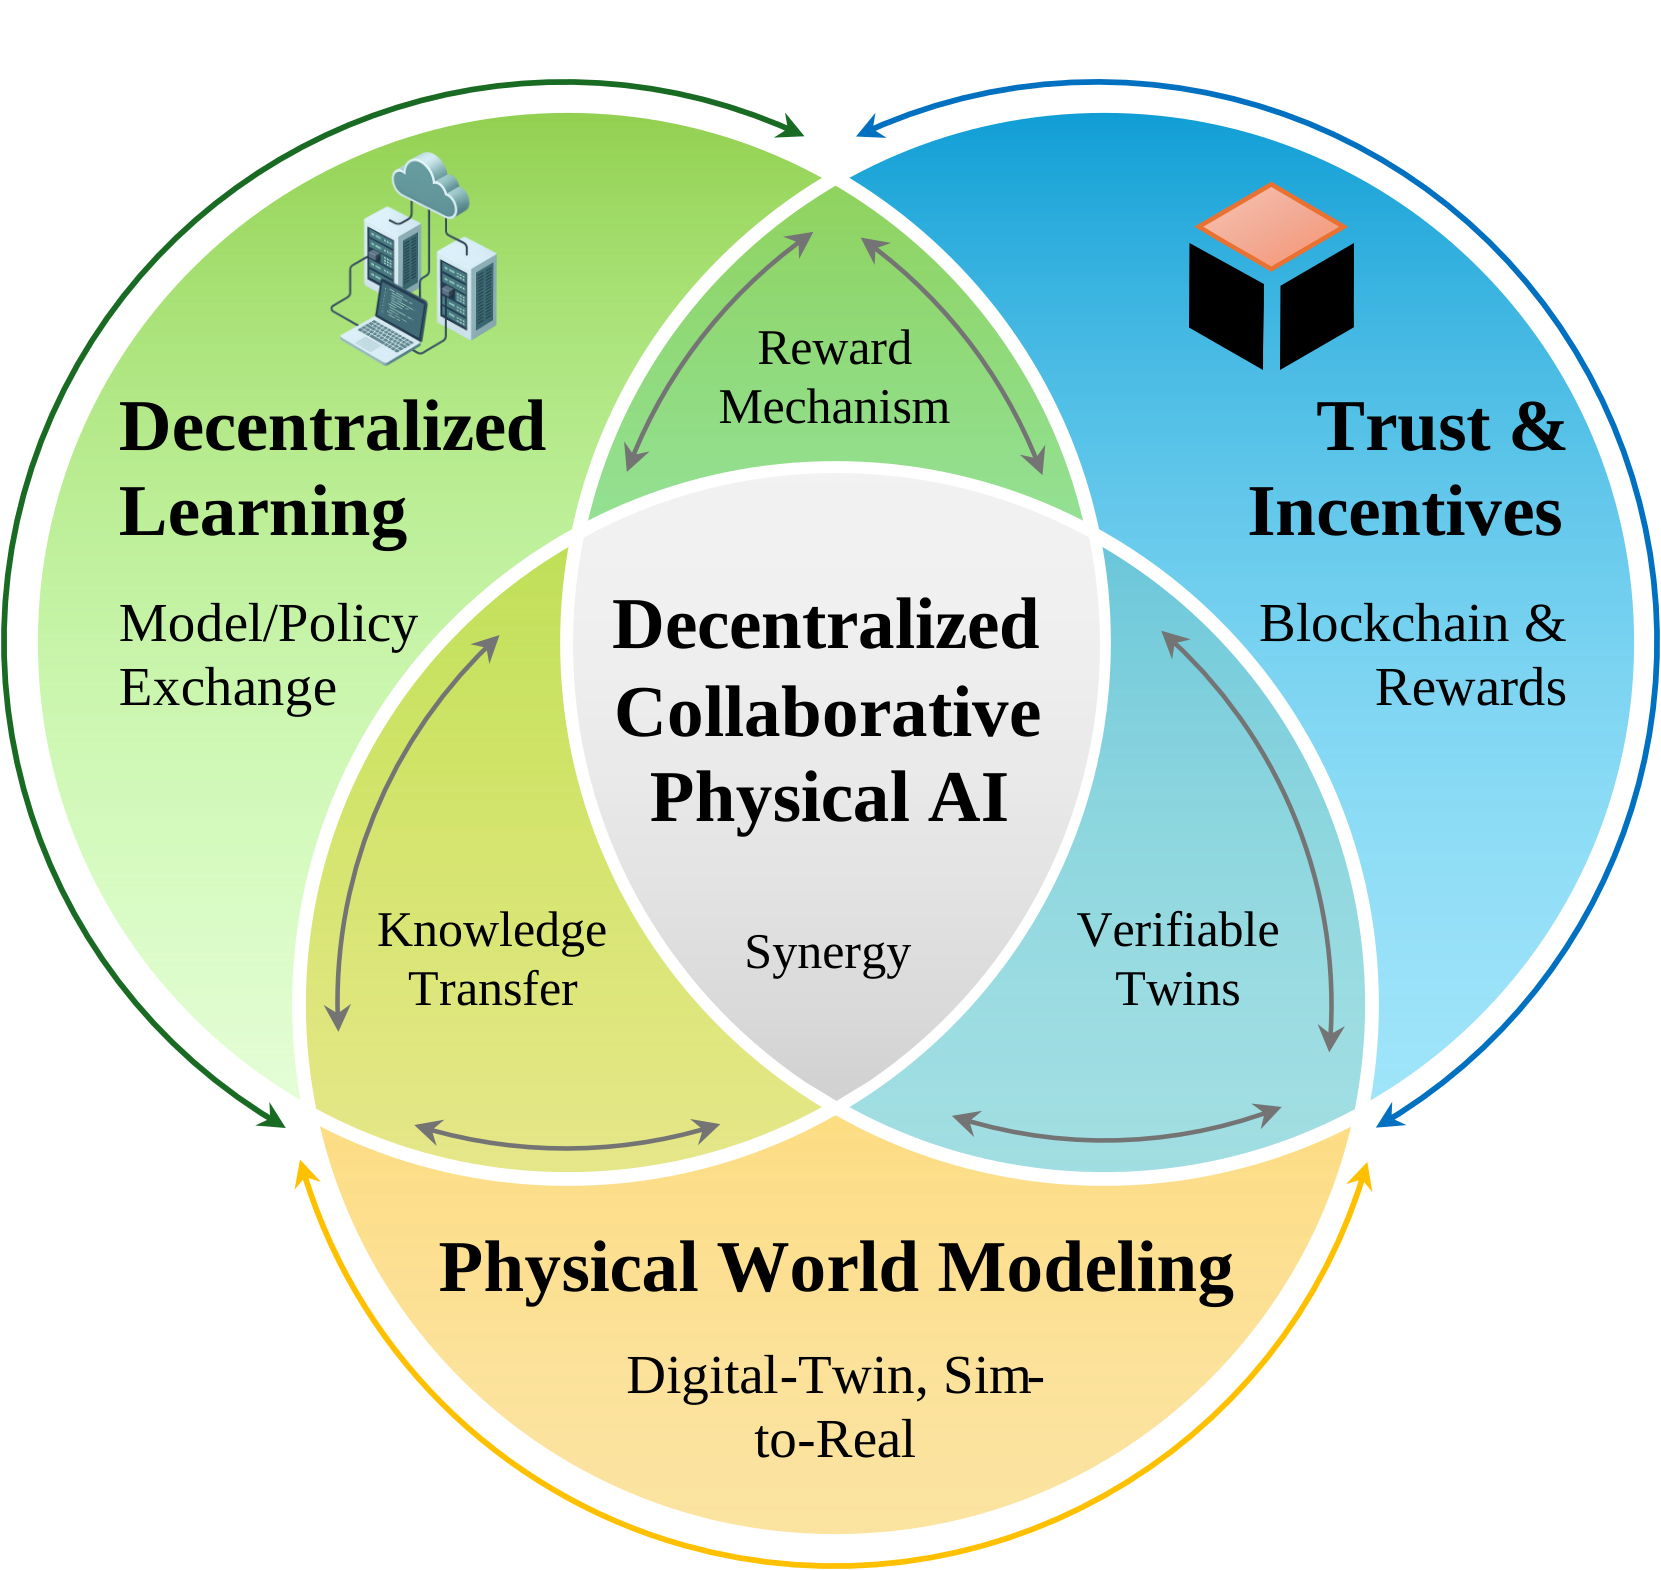
Decentralized Collaborative Physical AI
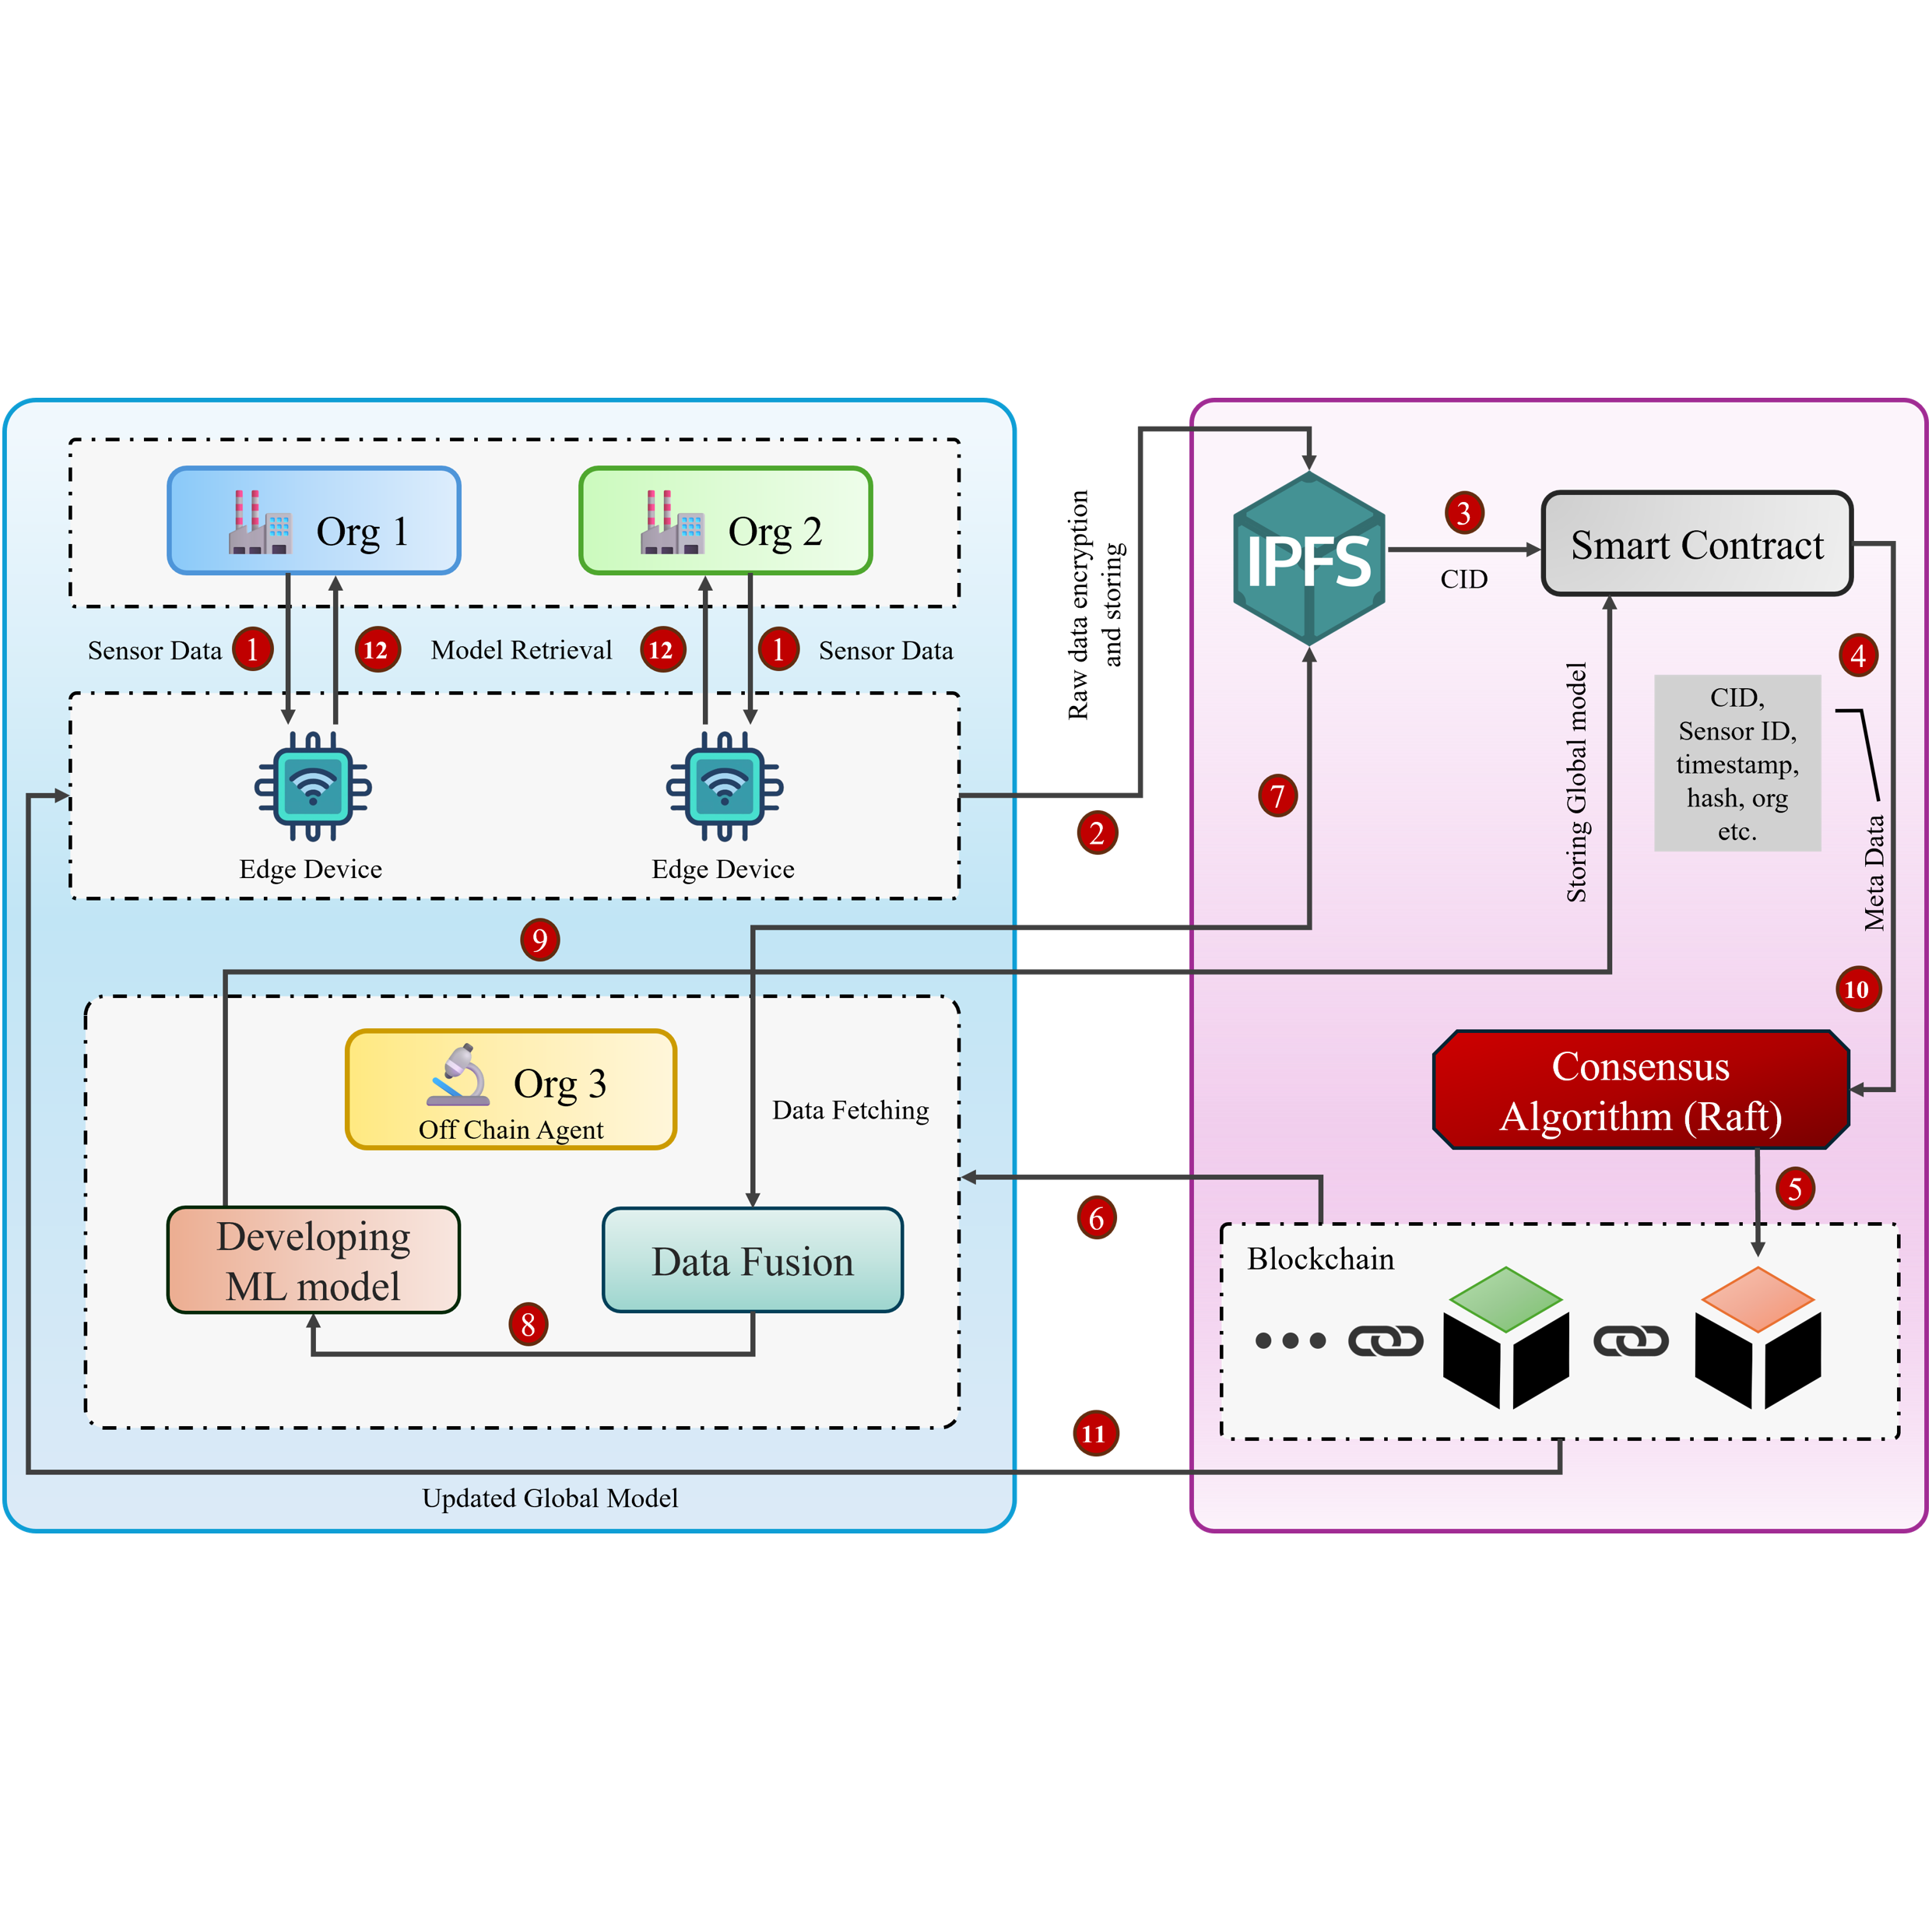
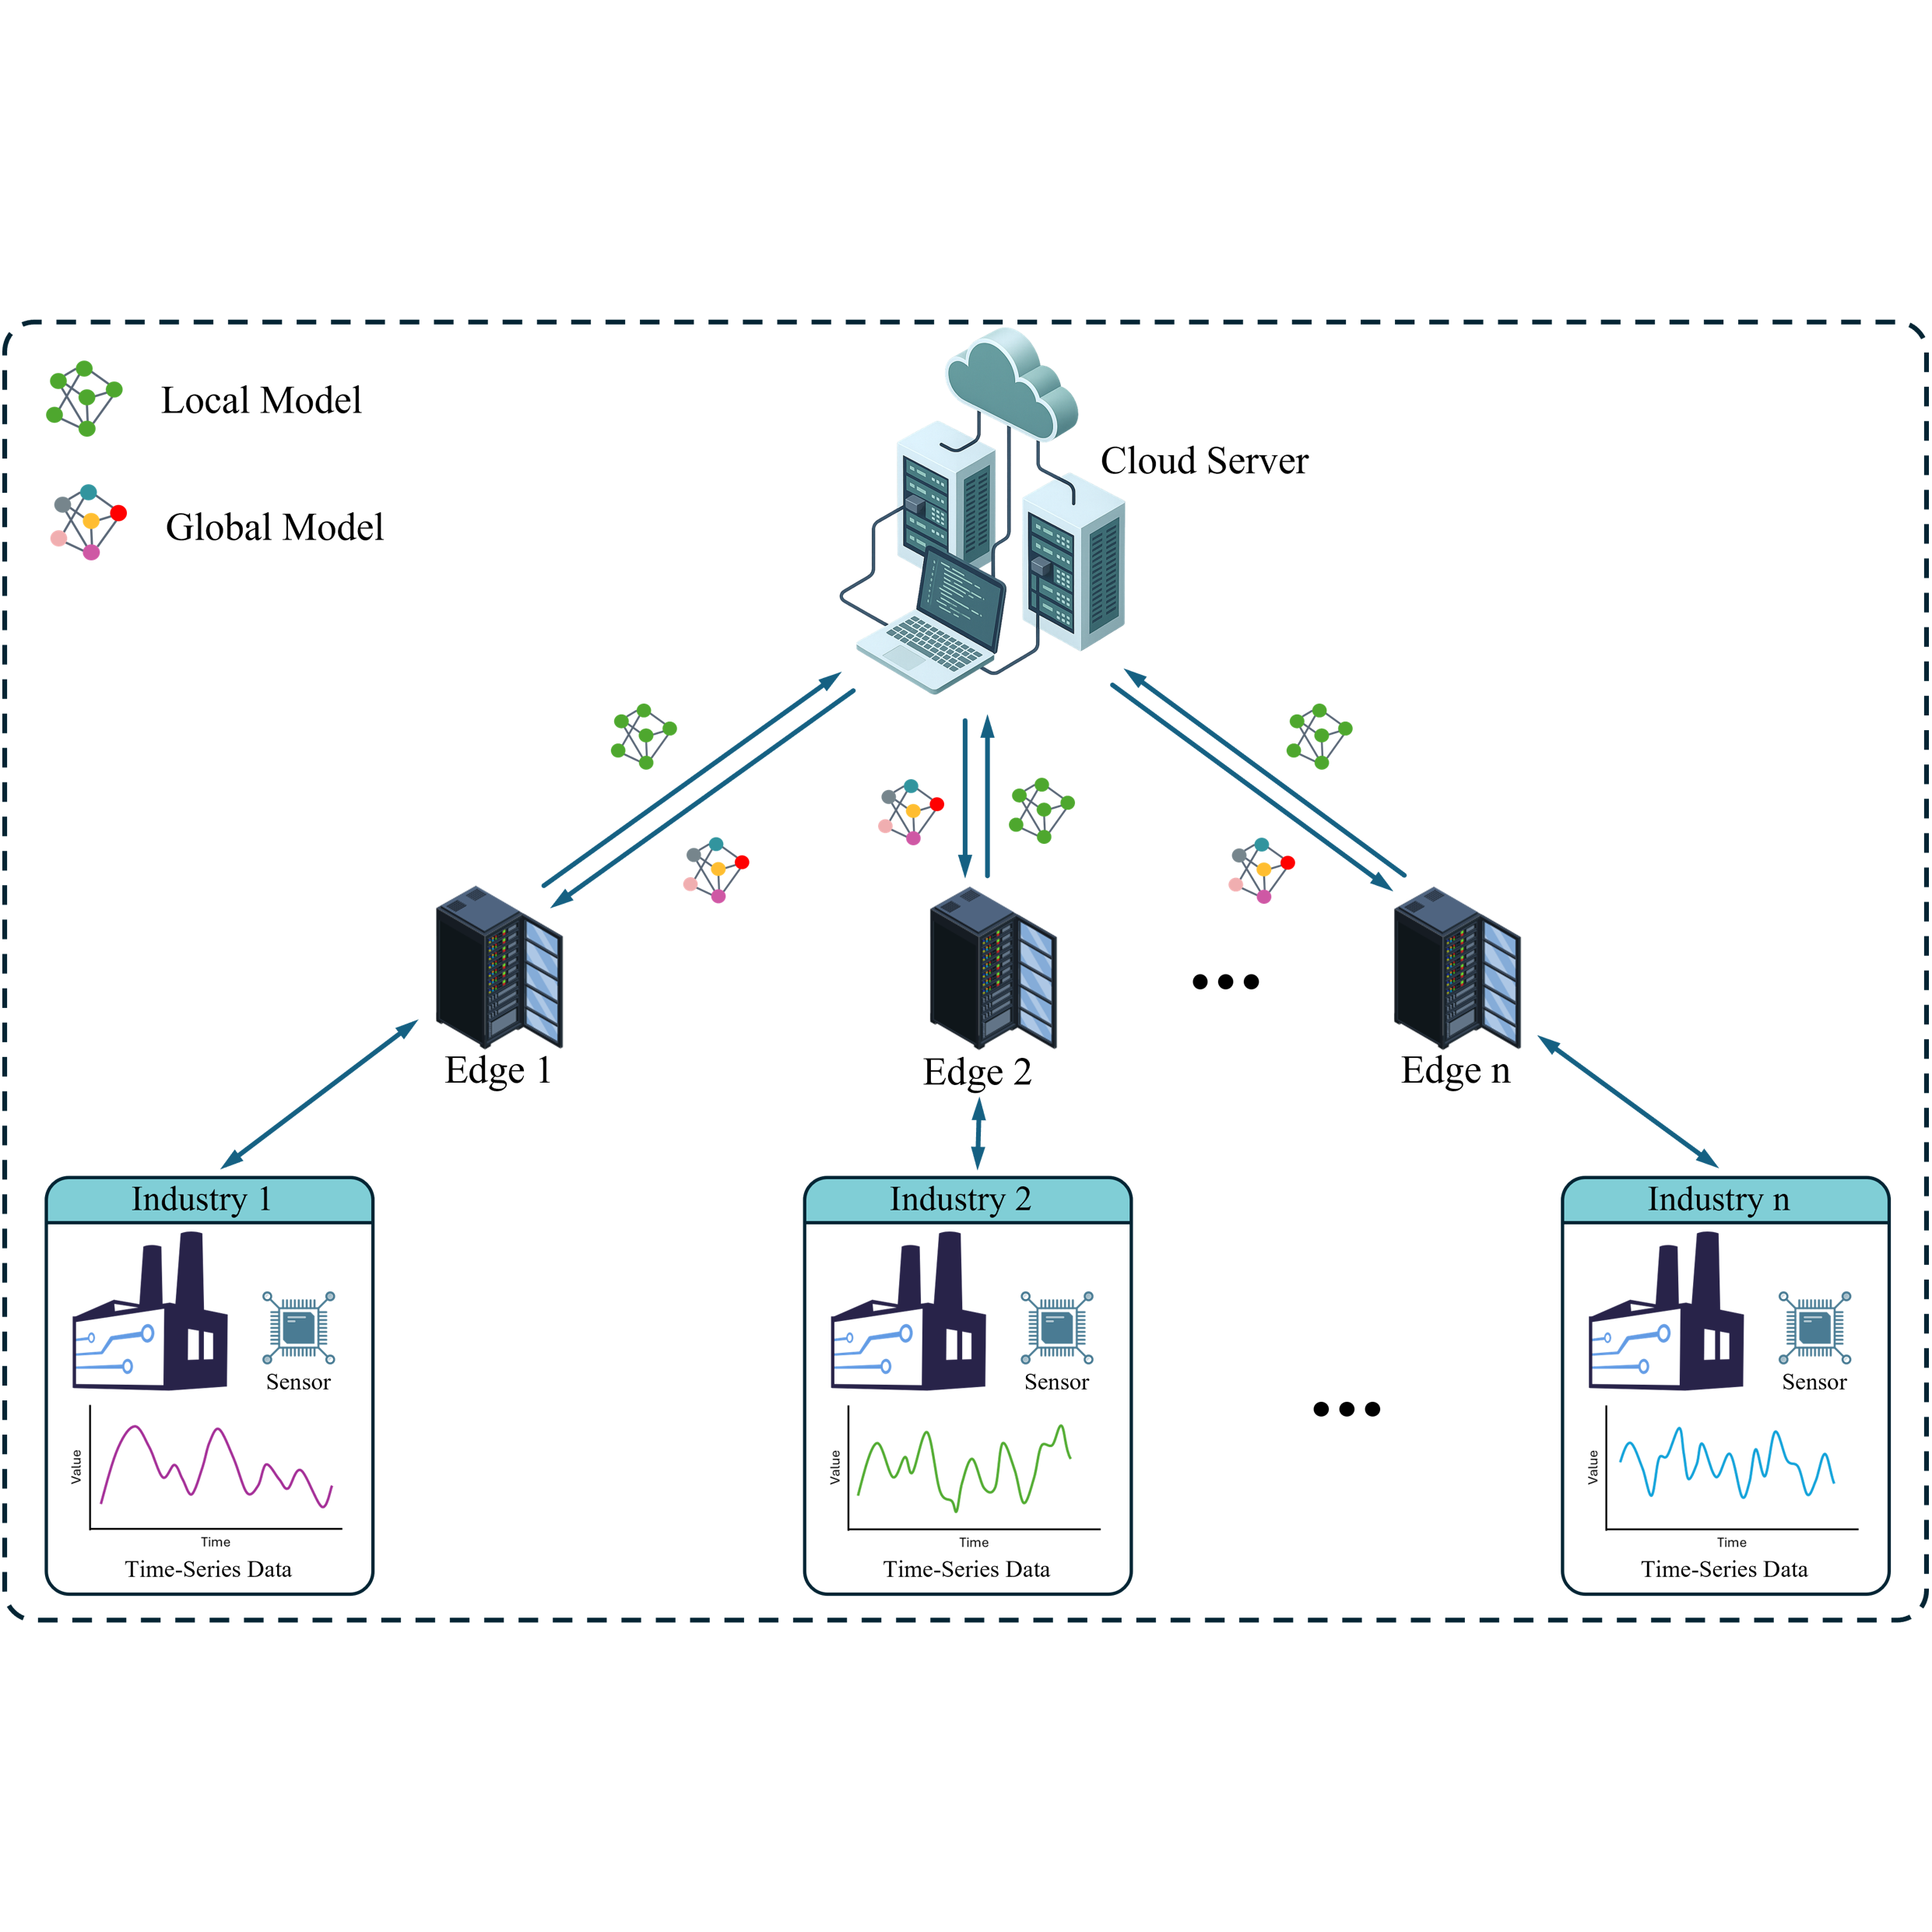
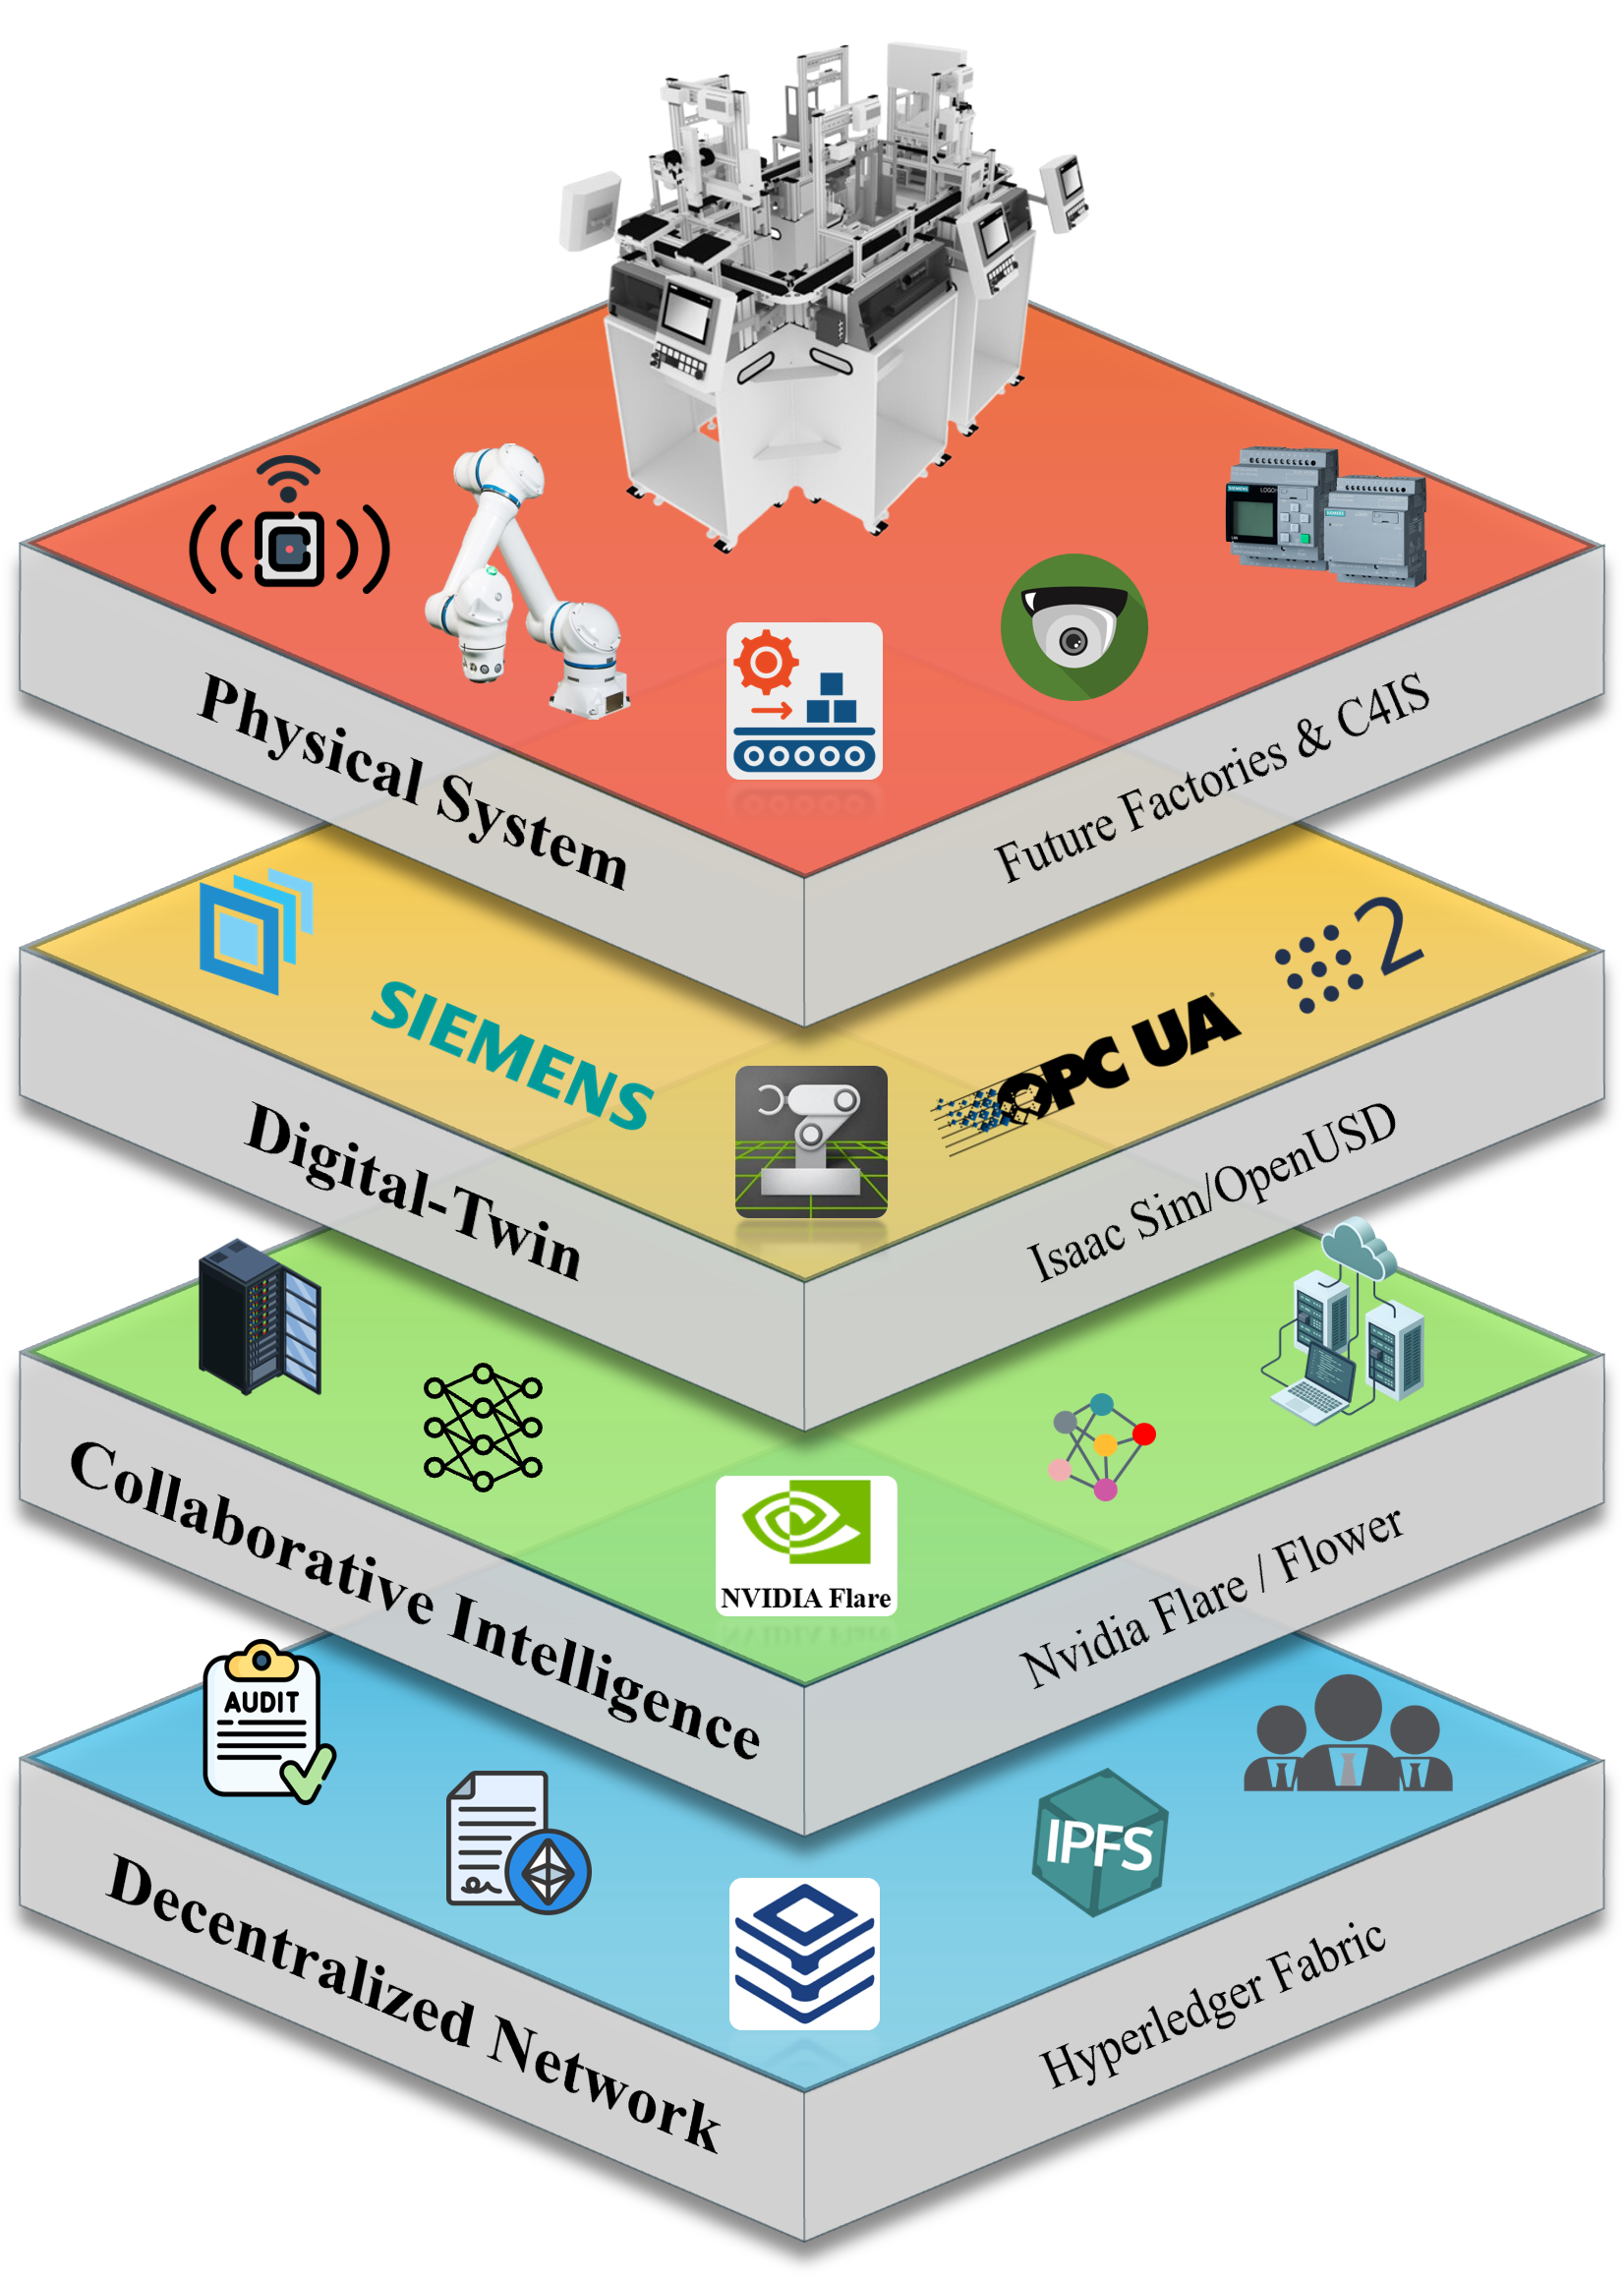
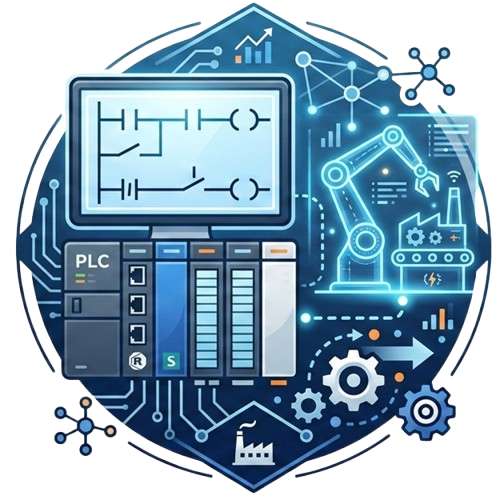
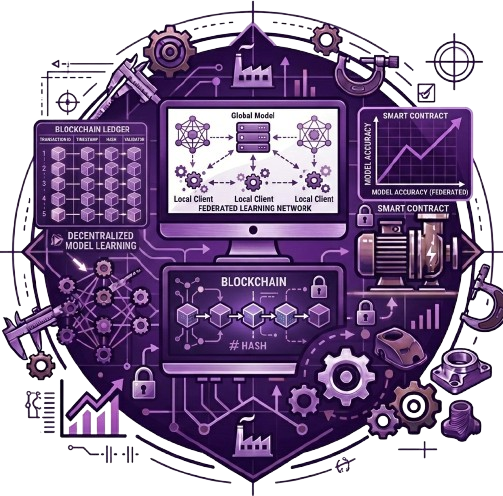
Developing an incentive-driven, blockchain-enabled decentralized federated-learning framework for collaborative Physical AI in distributed manufacturing. The work combines a robotic testbed, physical-virtual environment, edge-based learning services, and a permissioned blockchain so manufacturers can collaboratively improve inspection and robotic-manipulation models without sharing proprietary operational data. Key research areas include decentralized coordination, contribution valuation and trust, rare-event data acquisition, and sim-to-real validation.